One platform for all your machine data
Data pipelines, hybrid cloud storage and compute, and third-party connections — built for robots, drones and IoT fleets.
How data flows through MerkleBot
From sensor to insight, every hop is encrypted, hashed and observable.
Every robot, one pipeline
Connect your ROS robot's data, as well as a wide range of hardware, like KUKA, Mitsubishi Electric, Universal Robots, Boston Dynamics and IoT fleets. The MerkleBot Agent records what matters, buffers offline and uploads over resumable, bandwidth-aware channels.
- ROS 1 & ROS 2 topics, rosbag2 with MCAP storage
- Industrial controllers via vendor SDKs and OPC UA
- Boston Dynamics Spot SDK, PX4/MAVLink drones, MQTT devices
- Event-triggered recording and snapshot buffers
- Rich metadata: robot, site, mission, software version
Hybrid cloud, priced for robotics
Adopt the latest trends in secure, decentralized communication technologies to optimize cloud costs and avoid single points of failure. We combine edge compute with local data center providers and use idle resources just at the right time to reduce data throughput and cloud costs.
- Hot / warm / archive tiers with automatic lifecycle
- Decentralized archive with content addressing
- Client-side encryption, customer-managed keys
- Docker jobs on edge, local DC or cloud
- Pre-built ROSbag extractors for video, logs and Parquet
Data that works for your business
Extend the capabilities of your equipment by connecting the data to third-party services for monitoring, analytics, payments and financing. Webhooks and connectors push the right data to the right system — no extra ingestion stack.
- Monitoring & alerting: Grafana, chat and email via webhooks
- Analytics: data warehouses, BI tools, notebooks
- Payments: usage records for invoicing and billing
- Financing: Smart Lease robot-as-a-service plans
- AI services: inference and training pipelines
Verifiable by design
Named after the Merkle tree — the data structure that makes tampering evident.
Encrypted end to end
Data is encrypted on the device or gateway before upload. You control the keys; storage providers only ever see ciphertext.
Tamper-evident
Batches are sealed with Merkle roots signed by device keys. Inclusion proofs show any record belongs to an untouched batch.
How it worksNo single point of failure
Content-addressed objects can be replicated across independent providers and verified on retrieval by their hash.
Supported hardware & frameworks
Connect your ROS robot's data, as well as a wide range of hardware, like KUKA, Mitsubishi Electric, Universal Robots, Boston Dynamics and IoT fleets.
Spot SDK data, missions and payload cameras.
RTDE streams, programs and process data.
Controller logs, cycle counts and joint data.
ros2_control, MoveIt and rosbag2/MCAP.
Thermal, acoustic and visual inspection data.
ULog flight logs, telemetry and payload imagery.
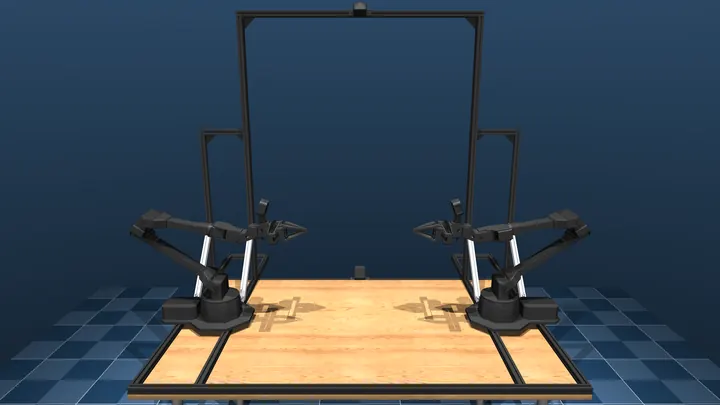
Multi-camera demonstrations for AI training.
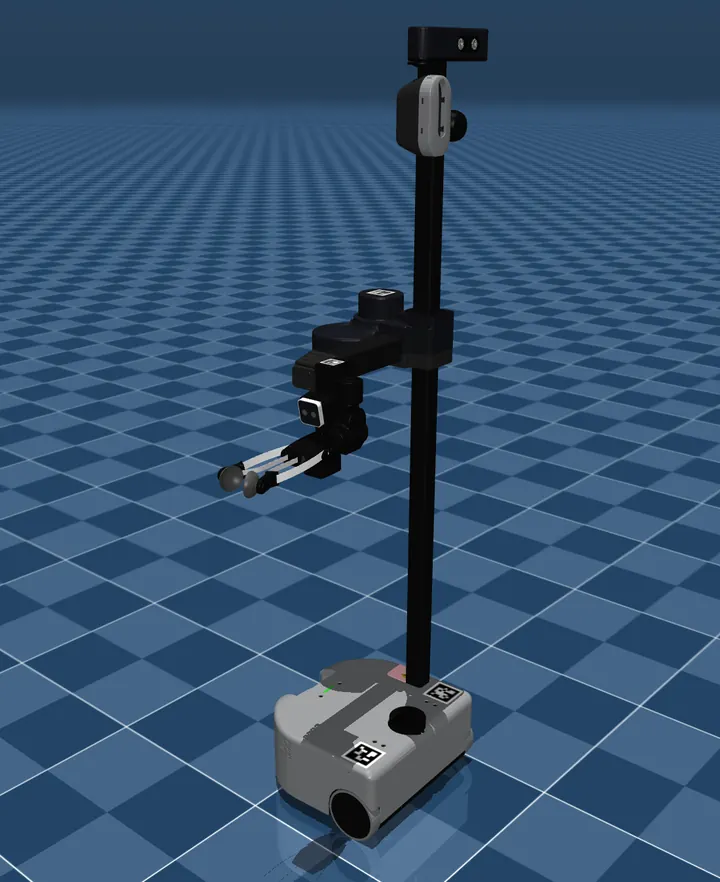
Navigation, mapping and manipulation logs.
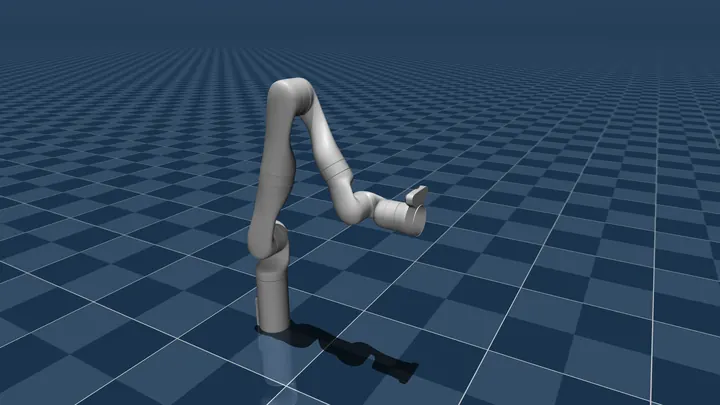
Vision module streams and joint telemetry.
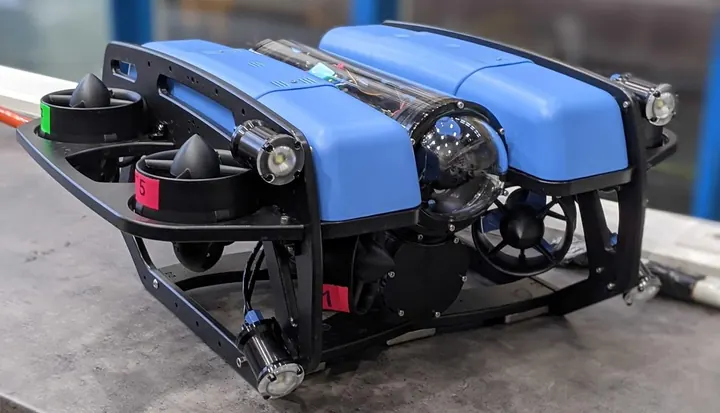
Sonar, video and depth telemetry.
Onboard the way that works for you
# 1. Install the CLI and log in
pip install merklebot-cli
mb login

# 2. Register a robot and install the agent
mb devices add --name ur5e-cell-03 --site warehouse-b
mb agent install --device ur5e-cell-03

# 3. Record ROS 2 topics to MCAP and sync to hybrid storage
mb pipelines create --device ur5e-cell-03 \
   --source ros2 --topics "/camera/.*,/joint_states,/tf" \
--format mcap --compression zstd --storage hybrid# Query recordings with the REST API
curl -s https://api.merklebot.com/v1/recordings \
-H "Authorization: Bearer $MB_TOKEN" \
-G --data-urlencode "device=ur5e-cell-03" \
--data-urlencode "from=2026-10-01T00:00:00Z" \
--data-urlencode "event=gripper_stall"from merklebot import Client
mb = Client(token="MB_TOKEN")
# Run a pre-built extractor on every new bag from a device
mb.extractors.attach(
device="ur5e-cell-03",
extractor="rosbag-video",
params={"topic": "/camera/color/image_raw", "fps": 15},
)
for rec in mb.recordings.search(event="gripper_stall", last="7d"):
print(rec.id, rec.cid, rec.video_url)Ready to put your machine data to work?
In a 30-minute demo we'll map your fleet's data flows and show where hybrid storage and compute cut costs.